Posts

Hub Motor CAD Photo Dump:

Image
  Four-part - Hyperion Mk2: This is probably my most refined hub motor design, utilizing a thin quadcopter motor over airplane motors, characterized by long lengths (00xx). It doesn't have a shaft and instead runs a 10-32 bolt along the length of the two static hubs, giving preload to the motor and bearings. However, the bolt being embedded in the hub results in loads being transferred to bolts as opposed to a shaft.  Four-part -Chronus: This design uses a Propdrive V2 5050, meaning the hub motor has to be quite wide to compensate for the large motor. One-part - Chronus: This was the original design for my hobbyweight's hub motor, but I decided to revamp it to the above design after seeing the success of Luke Quin's Kitten Mittens.  One-part - Hyperion Mk1: This was my original hub motor design, which was used successfully in my antweight Hyperion. I didn't have any issues with the one-part design; plus, it had super low friction.  Two-part - Uranus: This was my firs...

Team Carbon's November Necrosis Event report

Image
November Event Report     A few months ago, Titan and Hyperion, my two antweight combat robots, had their first combat robotics event. Though both robots did well, with Titan winning the antweight rumble, there's some room for improvement.       Only right before Titan's first fight, it finally clicked that there was an issue in the weapon system. As I was loading the bot into the arena, I was already thinking ahead to the necessary repairs and how to go about with them in the most efficient manner. The opposing robot was called Chopper, built by Andy Hedge, a returning competitor known for untraditional yet effective designs. Chopper has two light vertical spinners driven by a single motor along with an aluminum scoop down the center. This scoop ended up being super effective, and Titan's less-flush wedge (Without the "beak" shown in the picture) was no match for it. The light vertical spinners only caused cosmetic damage, but they acted as flippers which ...

Chronus Heavy - The Design

Image
Chronus Hobby - My 12lb Combat Robot By: Julien Mott     Chronus is a design that I've worked towards for quite a while. I wanted to engineer something unique to other designs and my own—opening myself to that beyond my comfort zone while utilizing what is within. CNC milling, hub motors, and non-planar surfaces are a few sophisticated design constraints, but my duality simultaneously geared me to build the biggest and most powerful machine within my capabilities. Hundreds of amps to draw, over 3KJ of KE, 4lb (1/3 weight budget) allocated to the weapon assembly, and bronze anodization are a few unsophisticated design constraints     Chronus Hobby was designed with goals distinguished before the actual geometric deficient were collated and corrected, which consist of: The weapon being hub-motor driven, the robot to feature absolute use of BLDC technology, titanium to be used in the place of AR500 steel for armoring, and 3D printing technology to be implemented without...

Hyperion - The Design

Image
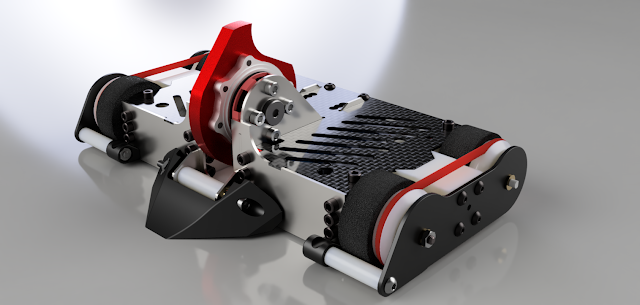
         Hyperion is my fourth antweight (454g) combat robot.      Combat robotics is a design engineering competition where builders compete their weight budgeted creations in head-to-head matches, following similar rules to boxing. A key difference between boxing and robotic combat are the educational benefits of the latter, giving valuable knowledge in various fields such as Mechanical Engineering, Electrical Engineering, Chemical Engineering, Etc.          Hyperion was born out of a desire to create a balanced machine—something that would be desirable in the real world. To do so, Hyperion uses 4WD, a compact weapon system to lower COM, indirect drive, a CNC Milled Hub motor system, an additively manufactured poly-amide unibody, titanium for optimal strength/weight where high hardness is needed, and brushless motor technology. The hub motor:     Hyperion's hub motor...